


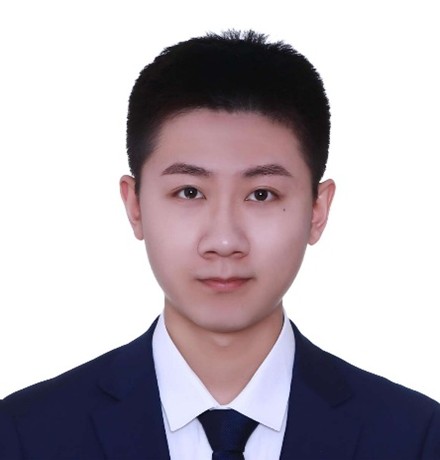
胡博
讲师,工学博士邮箱:hubo@btbu.edu.cn
个人简历
胡博,工学博士,讲师。主要从事机器人化显微操作,非线性控制,复杂系统建模等方向研究。以第一作者身份在国际高水平期刊和机器人领域顶会发表学术论文5篇。作为核心骨干参与国家重点研发计划课题等科研项目。担任电子与信息学报、IEEE Transactions on Systems, Man and Cybernetics: Systems、IEEE Transactions on Industrial Informatics、IEEE Transactions on Transportation Electrification、IEEE Transactions on Automation Science and Engineering等期刊审稿人。
研究方向
机器人化显微操作,非线性控制,复杂系统建模
教育经历
2022.09 - 2026.06 南开大学 控制科学与工程 工学博士
2018.09 - 2021.06 北京工商大学 控制理论与控制工程 工学硕士
2014.09 - 2018.06 北京工商大学 自动化 工学学士
学术成果
论文:
1. Bo Hu, Ruimin Li, Shiyu Xu, Rongxin Liu, Zengshuo Wang, Mingzhu Sun*, Xin Zhao*. Robotic micropuncture with preload strategy for retinal vein cannulation. IEEE/ASME Transactions on Mechatronics, 2026, 31(1): 512-522.
2. Bo Hu, Shiyu Xu, Rongxin Liu, Xin Zhao, Mingzhu Sun*. An adaptive finite-time sliding mode control for retinal vein micro-puncture with silicon phantom. IEEE Transactions on Automation Science and Engineering, 2025, 22: 5757-5768.
3. Bo Hu, Shiyu Xu, Lu Liu, Rongxin Liu, Mingzhu Sun, Xin Zhao*. Adaptive self-evolving extreme learning machine-based terminal sliding mode control with application in retinal vein injection. Engineering Applications of Artificial Intelligence, 2025, 152: 110789.
4. Bo Hu, Ruimin Li, Shiyu Xu, Rongxin Liu, Zengshuo Wang, Mingzhu Sun*, Xin Zhao*. Nonlinear viscoelastic model-based deformation optimization for robotic micropuncture in retinal vein cannulation. Proceedings of 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). IEEE, 2025: 11464-11470.
5. Bo Hu, Huiyan Zhang, Xiaoyi Wang*, Li Wang, Jiping Xu, Qian Sun, Zhiyao Zhao, Lei Zhang. DHESN: A Deep Hierarchical Echo State Network Approach for Algal Bloom Prediction. Expert Systems with Applications, 2024, 239: 1223291.
6. Huiyan Zhang, Bo Hu, Xiaoyi Wang*, Jiping Xu, Li Wang, Qian Sun, Zhaoyang Wang. Self-organizing Deep Belief Modular Echo State Network for Time Series Prediction, Knowledge-Based Systems, 2021, 222: 107007.